3D vision guided depalletizing
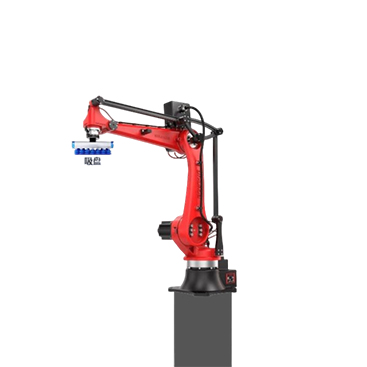
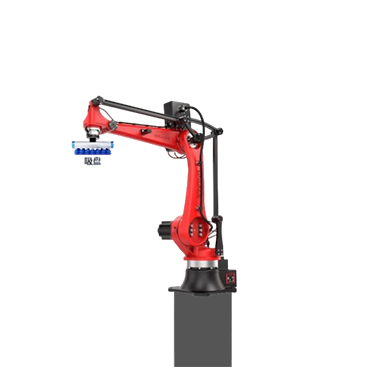
In order to improve transportation efficiency, various raw materials and parts are usually stacked into stacks for circulation. Under the traditional production model, users need to recruit a large number of porters to dismantle the stacks to designated warehouses, workstations or sorting conveyor belts. The labor intensity of workers is high, and the work content is mechanical and repetitive. At present, it is difficult to recruit general workers, so it is imperative to use robots to replace manual work to complete mechanized depalletizing. The 3D visual positioning system can guide robots to complete the dismantling of various materials and pallet types such as cartons, soft bags, sacks, turnover boxes, pallets, etc., greatly improving the efficiency and intelligence of depalletizing.
、